Glunova Biotech
Hiwonder NexArm All-Metal 6-Axis Robot Arm for LeRobot, 65 kg·cm Magnetic-Encoder Servos, 500 g Payload, Leader + Follower Imitation-Learning Kits
Hiwonder NexArm All-Metal 6-Axis Robot Arm for LeRobot, 65 kg·cm Magnetic-Encoder Servos, 500 g Payload, Leader + Follower Imitation-Learning Kits
Couldn't load pickup availability
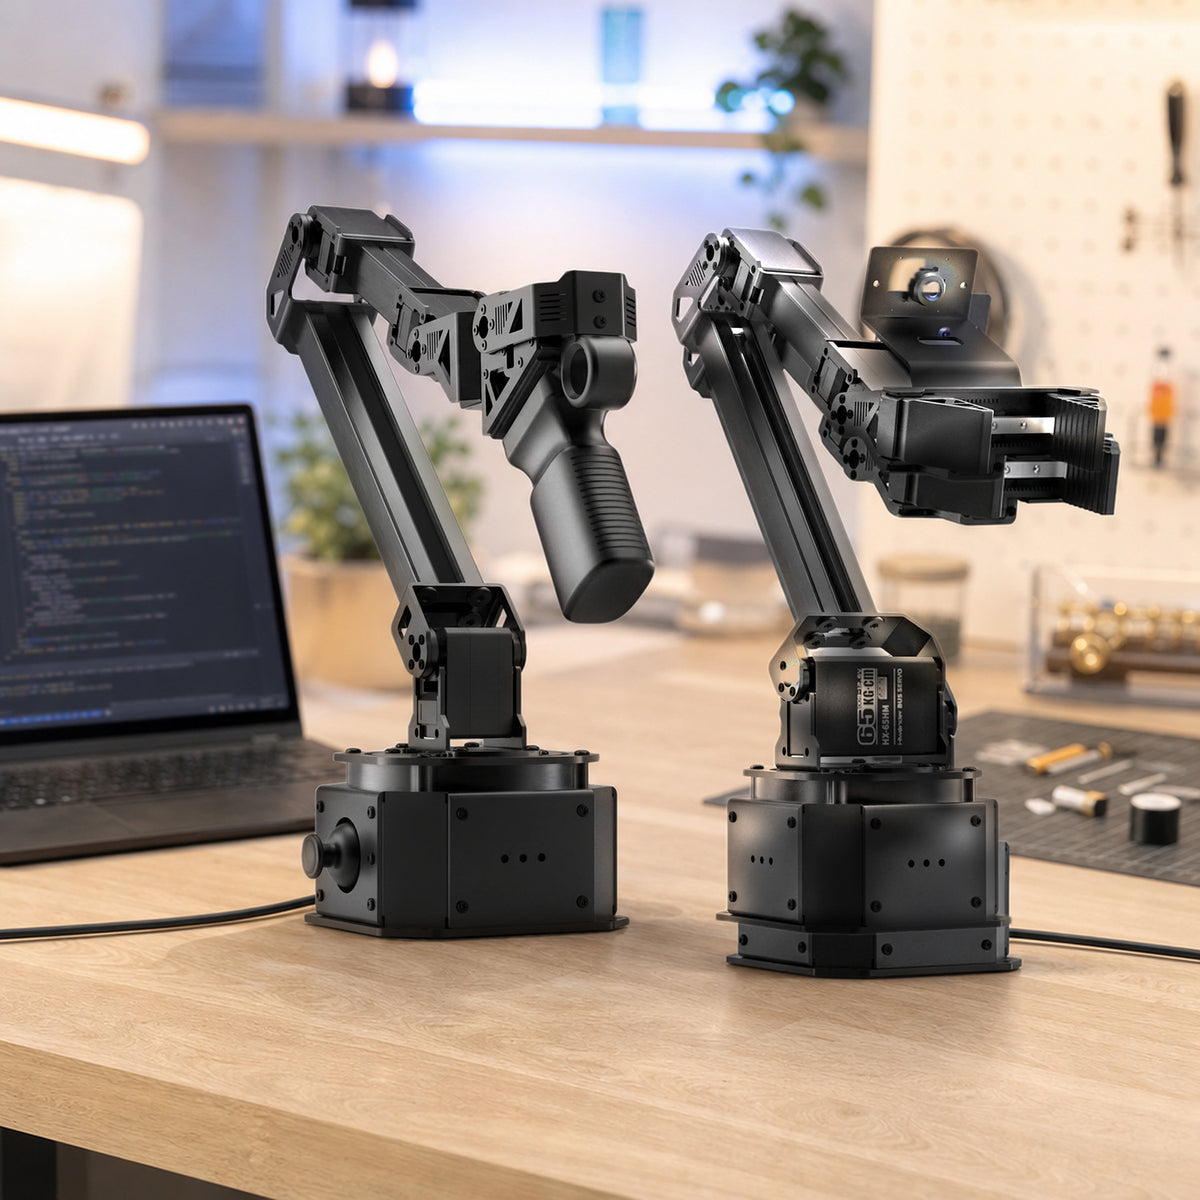
NexArm is an all-metal, open-source 6-axis desktop robot arm from Hiwonder built for embodied-AI and imitation-learning work: it keeps the SO-ARM101 servo protocol and LeRobot compatibility but replaces printed plastic with aluminium, 65 kg·cm magnetic-encoder servos, a parallel-rail gripper, 500 g payload and ±2 mm repeatability for research that needs to run for hours without wobble.
NexArm is a step up from 3D-printed SO-101 arms: an all-metal desktop arm with 65 kg·cm magnetic-encoder servos, a 500 g payload and ±2 mm repeatability, while keeping the same servo protocol so it drops straight into Hugging Face LeRobot workflows. Buy a single follower for autonomous tasks, or the leader + follower kits with cameras for teleoperation, data collection and imitation learning.
What can you use it for?
- Imitation learning and VLA policy training with Hugging Face LeRobot on more rigid hardware
- Leader–follower teleoperation and dual-view (wrist + overhead) dataset collection
- Pick-and-place, stacking and sorting of real objects up to 500 g
- University and corporate robotics labs that need repeatable, long-duration experiments
- Upgrading from SO-ARM101: same protocol, same workflows, metal body and stronger servos
Who is it for?
Research groups, robotics educators and serious builders who have outgrown 3D-printed arms and want an affordable metal arm that still speaks LeRobot.
Compatibility
- Software: Hugging Face LeRobot (Feetech / SO-ARM101 protocol), Hiwonder PC host software (3D view, action groups, coordinate mode), Python API, ROS-compatible controller variants exist
- Hosts: Windows or Ubuntu laptop, Raspberry Pi, NVIDIA Jetson
- Cameras: included USB UVC cameras in the kits; any OpenCV webcam can be added
- Pairing: one leader controls one follower; the follower alone can run trained policies or scripted motions
Specifications
| Model | Hiwonder NexArm (imitation-learning version) |
|---|---|
| Degrees of freedom | 6 (5 joints + parallel gripper) |
| Structure | Aviation-grade aluminium alloy, hidden internal wiring, patented parallel linear-rail gripper with silicone pads |
| Servos | HX-65HM 65 kg·cm dual-shaft magnetic-encoder bus servos (base and shoulder), HX-30HM and HX-12H on the wrist and gripper; 12-bit encoders, 0.3° precision |
| Gear ratios | Leader arm 1:147 (light, fast to move by hand); follower arm 1:345 (torque and holding) |
| Reach / payload | 500 mm working radius, 500 g rated payload, ±2 mm repeatability |
| Joint range | Base 270°, shoulder 200°, elbow 240° (see drawing) |
| Controller | ESP32 + AT32 dual-chip board with OLED display, trapezoidal acceleration and curve-smoothing motion algorithms |
| Cameras | Basic kit: 480p wrist camera with bracket; Deluxe kit adds 2 MP (1080p) wide-angle overhead camera on a metal stand |
| Servo protocol | Fully compatible with the SO-ARM101 / Feetech bus protocol, works unmodified with LeRobot |
| Software | Hugging Face LeRobot (ACT, VLA), Hiwonder PC host software with 3D visualisation, action groups, coordinate control, Python API |
| Power | 12 V DC adapter per arm (included) |
What's in the box
- Follower arm (assembled, with gripper): 1 × NexArm follower arm with parallel gripper, ESP32 + AT32 controller, 12 V adapter, USB cable, documentation
- Leader arm (assembled, with handle): 1 × NexArm leader arm with handle, controller, 12 V adapter, USB cable
- Imitation-Learning Basic Kit (leader + follower + wrist camera): 1 × follower arm, 1 × leader arm, wrist (first-person) camera with bracket, adapters, USB cables, documentation and tutorials
- Imitation-Learning Deluxe Kit (+ overhead 2 MP camera and stand): Everything in the Basic Kit plus a 2 MP wide-angle overhead camera on a metal desk stand for third-person recording
Frequently asked questions
How is NexArm different from the SO-ARM101?
The SO-ARM101 is 3D-printed PLA with 30 kg·cm servos; NexArm is aluminium with 65 kg·cm servos, a 500 mm reach, 500 g payload, ±2 mm repeatability, hidden wiring and a parallel linear-rail gripper. Both use the same servo protocol and work with LeRobot, so datasets, scripts and habits carry over.
Does it work with Hugging Face LeRobot?
Yes. NexArm is fully compatible with the SO-ARM101 servo protocol that LeRobot supports, and Hiwonder provides configs and a step-by-step course covering teleoperation, recording, ACT training and deployment.
Which kit do I need?
For imitation learning you need a leader and a follower: choose the Basic Kit (wrist camera) or the Deluxe Kit (wrist plus overhead camera, the setup used in most tutorials). A single follower arm is enough for running trained policies, scripted pick-and-place, or coordinate-mode control from the PC software.
What is the payload and accuracy?
500 g rated payload at a 500 mm working radius with ±2 mm repeatability, thanks to 12-bit magnetic encoders and trapezoidal-acceleration motion control.
Is it assembled?
Yes. Every configuration ships assembled and factory-calibrated. Fix the base to the desk, connect 12 V power and USB, and it is ready.
Why do the leader and follower have different gear ratios?
The leader arm uses 1:147 servos so it is light and smooth to move by hand; the follower uses 1:345 servos for torque and holding. That is what makes teleoperation feel natural and the follower strong.
Share