ArmDojo
LeKiwi Mobile Base 3D-Printed Parts Set, Printed in Singapore (Made to Order): Holonomic Omni-Wheel Chassis for LeRobot SO-101, PLA+ with Heat-Set Inserts
LeKiwi Mobile Base 3D-Printed Parts Set, Printed in Singapore (Made to Order): Holonomic Omni-Wheel Chassis for LeRobot SO-101, PLA+ with Heat-Set Inserts
Couldn't load pickup availability
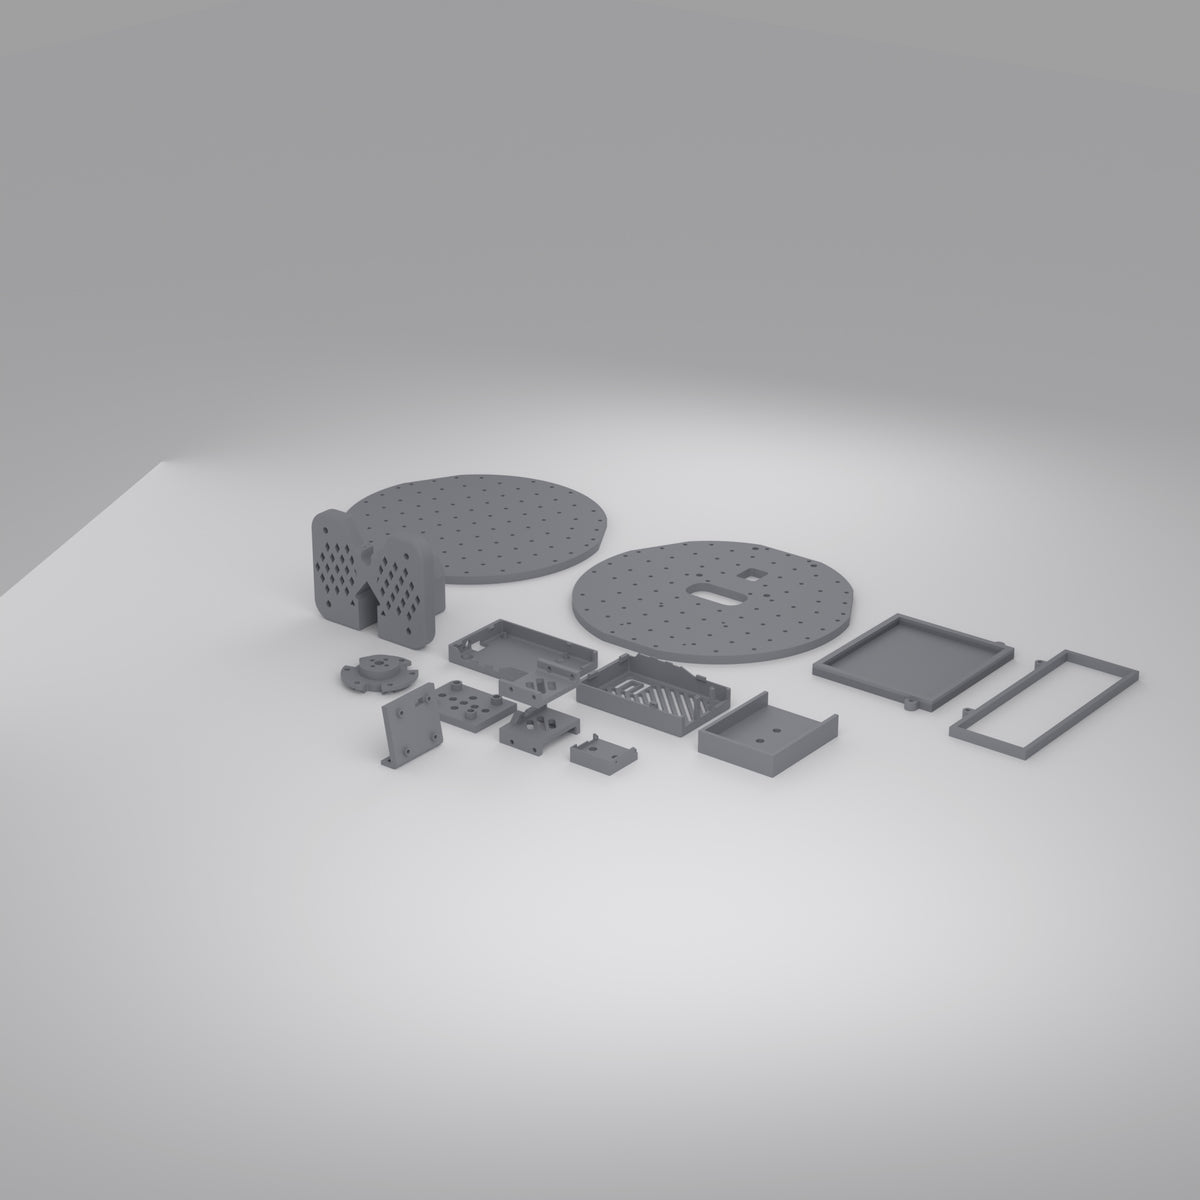
This is the complete set of 3D-printed structural parts for the LeKiwi mobile manipulator base — the open-source three-wheel holonomic chassis from SIG Robotics at UIUC that turns a LeRobot SO-100 / SO-101 arm into a mobile robot — printed to order in Singapore in PLA+, supports removed and M3 heat-set inserts fitted, including both base plates, three wheel hubs, three drive motor mounts, the Raspberry Pi 5 case, battery and power-bank mounts, Jetson holder, camera mount and the modified SO-101 arm base.
What can you use it for?
- Turning an existing SO-101 follower arm into a mobile manipulator
- Collecting LeRobot datasets that need the base to move, not just the arm
- Teaching holonomic (kiwi) drive kinematics with real hardware
- Lab and classroom builds where nobody has a 256 mm printer free for a day and a half
Who is it for?
LeRobot users who already run an SO-101 arm and want the mobile base, and labs whose printers are too small or too busy for the 216 mm base plates.
Compatibility
- Robot: LeKiwi as published by SIG Robotics UIUC, officially supported in Hugging Face LeRobot
- Arm: SO-100 / SO-101 follower — the modified arm base is included so the arm bolts straight on
- Drive: 3 × Feetech STS3215 servos and 3 × 4-inch omni wheels (both sold separately)
- Compute: Raspberry Pi 5 (case included) or NVIDIA Jetson Orin Nano (holder included)
- Electronics: Waveshare bus servo driver board, mount included
Specifications
| Material | PLA+, 0.2 mm layers, 15 % infill, printed on Bambu Lab hardware |
|---|---|
| Base plates | 216 × 213 mm, 7 mm thick, Ø3.5 mm mounting grid on 20 mm centres |
| Inserts | M3 brass heat-set inserts fitted where the assembly threads into plastic |
| Finish | Supports removed on the wheel hubs and arm base, the two parts that need them |
| Print time | About 34 h of machine time for the full set |
| Country of origin | Singapore (printed in-house) |
| HS code | 8487.90 |
| Lead time | 5–7 business days, then transit |
What's in the box
- Complete base set: 2 × base plate (top and bottom), 3 × drive motor mount, 3 × servo wheel hub, 1 × servo controller mount, Raspberry Pi 5 case (top and bottom), 1 × 12 V battery mount, 1 × 5 V power-bank holder, 1 × Jetson holder, 1 × base camera mount, 1 × modified SO-101 follower-arm base
Shipping and returns
Printed and dispatched from Singapore with tracking. Free standard shipping on orders over $25 to Canada, the UK, EU, Japan, Korea, Australia and most other countries (5–15 days); to the United States at carrier cost from $11.99. Because every set is printed to order, allow the lead time above before dispatch. 7-day returns; a mis-printed or warped part is reprinted or refunded with shipping covered. Import duties, where charged by your country, are paid by the recipient — these parts are declared Singapore origin, HS 8487.90.
Frequently asked questions
What is not included?
Everything that is not plastic: the three 4-inch omni wheels, three STS3215 servos, the Waveshare motor control board, the Raspberry Pi or Jetson, the M2/M3/M4 screw set, and a battery. We sell the servos and the Waveshare board separately.
Why is no battery supplied?
Lithium cells are restricted in air freight. The set includes mounts for both the 12 V battery and a 5 V USB power bank, so you can source either locally and bolt it straight on.
Why would I buy this instead of printing it?
The two base plates are 216 mm across and will not fit a 180 mm printer at all. Even on a 256 mm machine the full set is about 34 hours — a day and a half with the printer doing nothing else.
Does the SO-101 arm bolt straight on?
Yes. The set includes the LeKiwi-specific modified follower-arm base, so an SO-101 follower mounts to the top plate without any extra adapter.
Pi or Jetson?
Both mounts are in the set, so you can decide later. The upstream LeKiwi build uses a Raspberry Pi 5; the Jetson holder is there for people running heavier on-device inference.
Is the geometry modified?
No. These are the upstream LeKiwi STL files printed unmodified, so the official assembly guide and the LeRobot lekiwi configuration apply exactly as written.
Attribution
The part geometry is the open-source LeKiwi design by SIG Robotics at UIUC (Pepijn Kooijmans, Manav Chandaka, Bhargav Chandaka, Gloria Wang, Advait Patel), released under the Apache License 2.0, printed here unmodified. Source: github.com/SIGRobotics-UIUC/LeKiwi. ArmDojo supplies the printing, finishing and inserts; we do not claim authorship of the design and we are not affiliated with or endorsed by SIG Robotics, UIUC or Hugging Face.
Share