Glunova Biotech
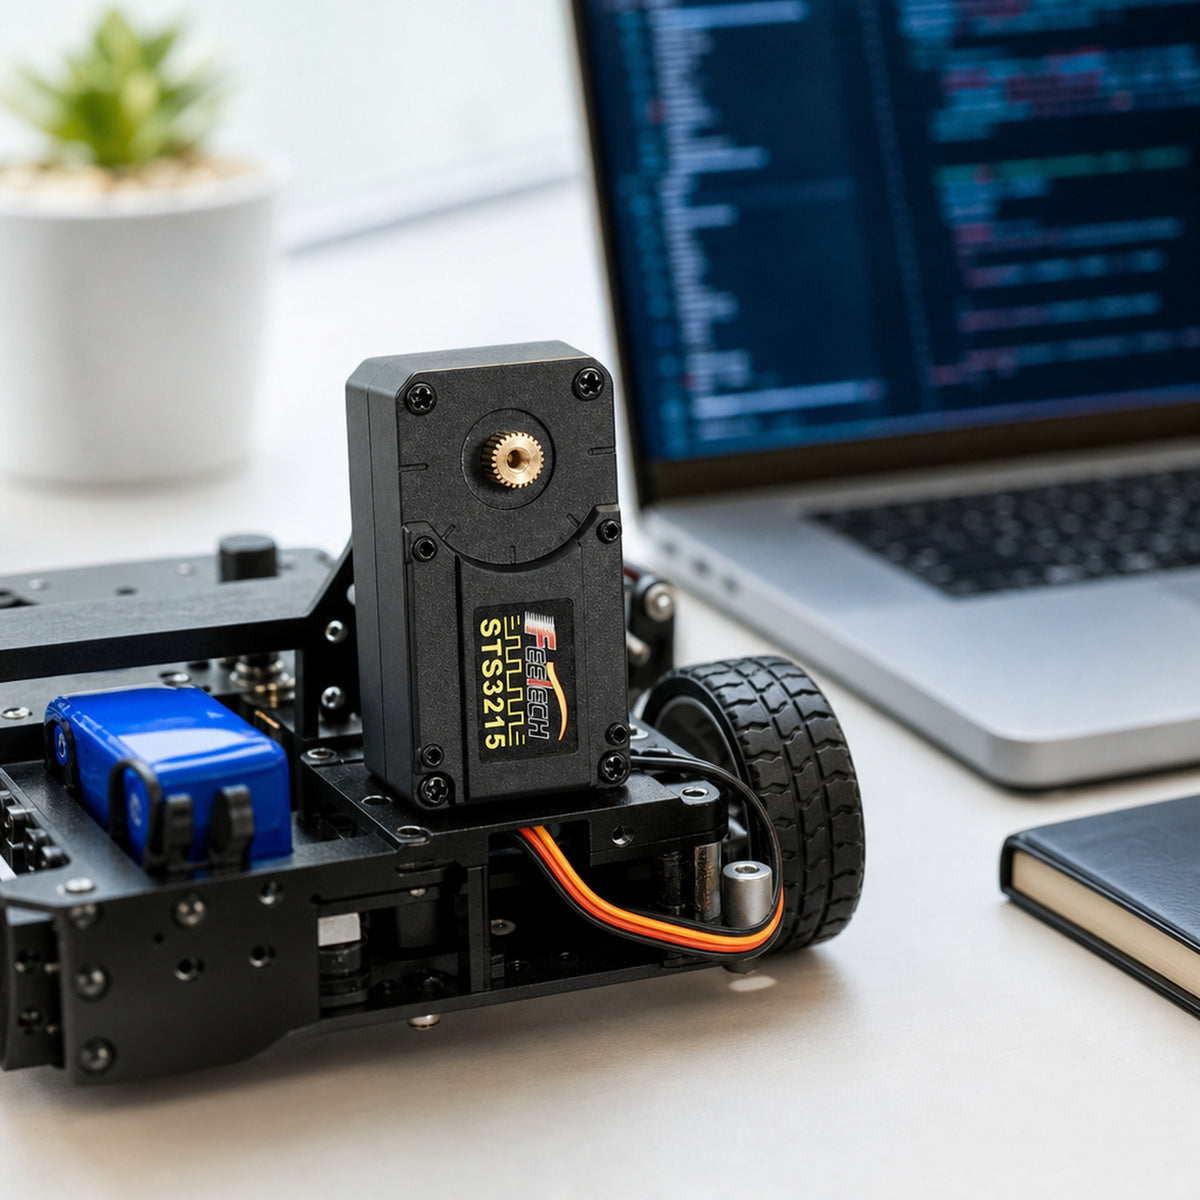
Feetech STS3215 Serial Bus Servo, 30 kg·cm 12 V / 19 kg·cm 7.4 V, 360° Magnetic Encoder, for SO-ARM101, LeKiwi, OpenDuck (single or robot sets)
Feetech STS3215 Serial Bus Servo, 30 kg·cm 12 V / 19 kg·cm 7.4 V, 360° Magnetic Encoder, for SO-ARM101, LeKiwi, OpenDuck (single or robot sets)
Couldn't load pickup availability
The Feetech STS3215 is a smart serial-bus servo with a 12-bit magnetic encoder, metal gears and 360° multi-turn position feedback that is the standard actuator of the Hugging Face SO-100 / SO-101 robot arms, the LeKiwi mobile manipulator and OpenDuck Mini, used wherever a project needs daisy-chained, position-feedback joints controlled from one serial port.
The STS3215 is the servo used in the Hugging Face SO-100 / SO-101 arms, the LeKiwi mobile manipulator and OpenDuck Mini. Buy singles to replace a joint, or pick a set that matches the exact voltage and gear-ratio mix the open-source build guides call for.
What can you use it for?
- Replacing or upgrading a joint in an SO-ARM100 / SO-ARM101 leader or follower arm
- Building an SO-101 arm from printed parts: the 12-servo set matches the official bill of materials
- LeKiwi mobile base (3 × 12 V wheel servos) or the full LeKiwi robot (base + arm)
- OpenDuck Mini bipedal robot (14 × 7.4 V servos)
- Custom robots, grippers and pan-tilt heads that need position, load and temperature feedback over one bus
Who is it for?
LeRobot builders sourcing exact-spec servos, robotics students, and makers who want feedback servos that are cheaper than Dynamixel but supported by open-source software.
Compatibility
- Controllers: BusLinker V3.0, Waveshare bus servo adapter, Feetech FE-URT-1, or any 3.3 V / 5 V UART with half-duplex direction control
- Software: Hugging Face LeRobot (feetech motor bus), Feetech FD software, Python (scservo_sdk), Arduino and ESP32 libraries
- Horns: 25 T spline, metal horns included; compatible with SO-101 and LeKiwi printed parts
- Voltage: C018 runs on 12 V (SO-101 follower joints); C001 / C044 / C046 run on 7.4 V (leader arm and light joints) — do not feed 12 V to the 7.4 V models
Specifications
| Model | Feetech STS3215 (ST3215) smart serial bus servo |
|---|---|
| Stall torque | C018: 30 kg·cm at 12 V; C001 / C044 / C046: 19 kg·cm at 7.4 V (1:345), lower on the faster ratios |
| Gear ratio | 1:345 (C018, C001), 1:191 (C044), 1:147 (C046) |
| Speed | 0.16 s/60° (C018 at 12 V); 52 rpm at 7.4 V for 1:345 models |
| Position sensor | 12-bit magnetic encoder, 4096 steps over 360°, 0.088° resolution |
| Control modes | Position (0–360°), constant-speed wheel, open-loop PWM, step mode, multi-turn absolute position |
| Interface | Half-duplex TTL serial bus, 38 400 bps – 1 Mbps, daisy-chain up to 253 IDs, 3-pin cable |
| Feedback | Position, speed, load, voltage, temperature, current, moving status; over-current and over-temperature protection |
| Voltage | C018: 6–12.6 V (use 12 V); C001 / C044 / C046: 5–8.4 V (2S LiPo or 7.4 V supply) |
| Gears | Metal (brass and steel), dual-shaft housing with rear bearing, 25 T spline |
| Size / weight | 45.2 × 24.7 × 35 mm, 55 g |
| Included per servo | Metal main horn, rear horn, horn screws, mounting screws, 15 cm 3-pin cable |
What's in the box
- STS3215-C018, 12 V, 30 kg·cm, 1:345: 1 × STS3215-C018 servo, metal main horn, rear horn, screws, 15 cm cable
- STS3215-C001, 7.4 V, 19 kg·cm, 1:345: 1 × STS3215-C001 servo with horns, screws and cable
- STS3215-C044, 7.4 V, 1:191 (fast): 1 × STS3215-C044 servo with horns, screws and cable
- STS3215-C046, 7.4 V, 1:147 (fastest): 1 × STS3215-C046 servo with horns, screws and cable
- SO-ARM101 12-servo set (6 × 12 V + 6 × 7.4 V, three ratios): 6 × C018 12 V for the follower, 6 × 7.4 V servos in the 1:345 / 1:191 / 1:147 mix the SO-101 leader arm calls for, horns, screws and cables
- LeKiwi base set (3 × 12 V, 1:345): 3 × STS3215-C018 12 V servos with horns, screws and cables
- LeKiwi full robot set (9 × 12 V + 6 × 7.4 V): 9 × 12 V and 6 × 7.4 V servos in the three LeKiwi gear ratios, horns, screws and cables
- OpenDuck Mini set (14 × 7.4 V, 19 kg·cm, 1:345): 14 × STS3215-C001 servos with horns, screws and cables
Frequently asked questions
Which STS3215 do I need for the SO-ARM101?
The follower arm uses six 12 V C018 (30 kg·cm) servos. The leader arm uses 7.4 V servos with three different gear ratios so it is light to move by hand: the 12-servo set on this page contains exactly the mix from the SO-101 bill of materials.
What is the difference between C018, C001, C044 and C046?
C018 is the 12 V, 30 kg·cm, 1:345 version. C001 is the 7.4 V, 19 kg·cm, 1:345 version. C044 (1:191) and C046 (1:147) are 7.4 V servos with lower gear ratios: faster and easier to back-drive, less torque; the SO-101 leader arm uses them for the joints you move most.
Is it a real Feetech servo?
Yes. These are genuine Feetech STS3215 servos with the Feetech label, magnetic encoder and metal gearbox, the same part sold by Seeed and Waveshare.
Can I control it from Arduino or Raspberry Pi?
Yes. It speaks the Feetech half-duplex serial protocol. Use a bus servo board such as the BusLinker V3.0 or a Waveshare adapter for USB, or a UART plus direction pin on a microcontroller with the Feetech SCServo library.
Does it do continuous rotation?
Yes. Besides 0–360° position mode it supports wheel (constant speed) mode, open-loop PWM mode, step mode and multi-turn absolute position, selectable by register.
What power supply do I need?
12 V 5 A for six C018 servos in an arm; 7.4 V (2S LiPo or a 7.4 V supply) for the C001 / C044 / C046 models. Each servo draws about 0.9 A rated and up to 2–3 A at stall.
Share